primo humanoid robot


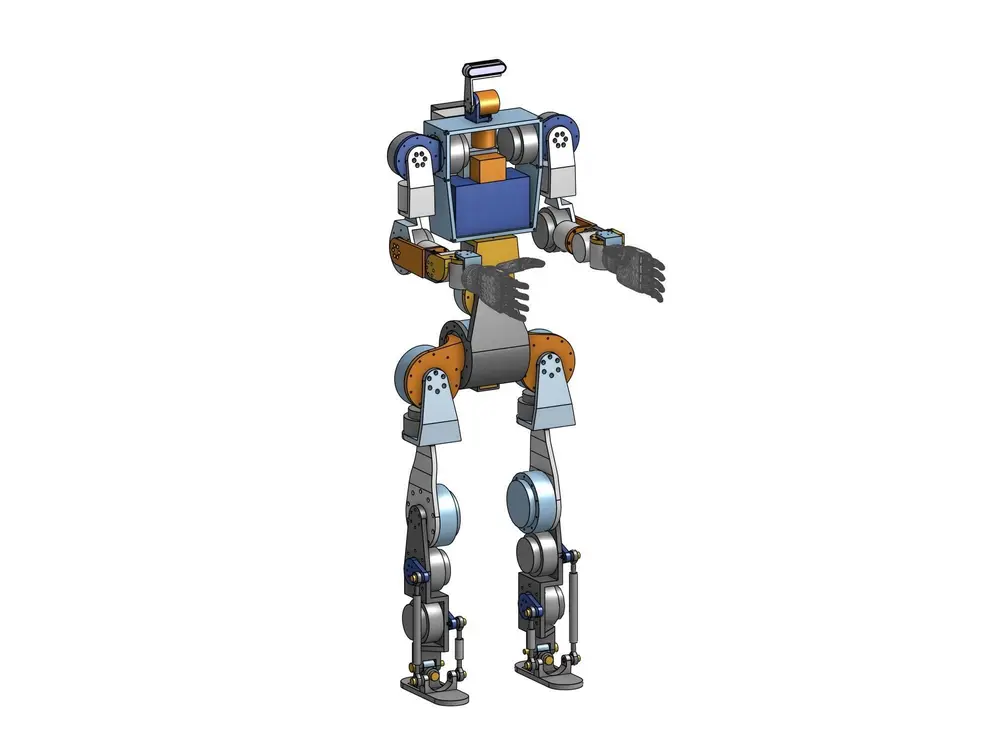
Primo is an open source humanoid. 3D printed structure in PA-CF, 30 RobStride quasi-direct-drive actuators, NVIDIA Jetson AGX Thor, Unitree G1 kinematics as reference. Height ≈ 1.40 m, ≈ 45 kg.
Video, CAD tour and walking in Isaac Lab: https://youtu.be/6nTcHpFmKbQ
Still in design, not built yet. Everything is shared to build it together: CAD, printable STL of the structure, bill of materials with links, electrical scheme, URDF, simulation files, walking policies in Isaac Lab and the handoff to continue the project, also with an AI.
Files here: the printed structure as STL (20 parts, left and right, millimetres, design state) and the first print projects as 3MF, the ankle offset gimbal and a leg test plate (femur, hip bracket, tibia). What is bought, motors, hands, battery, computer, screws, is in the bill of materials.
CAD: https://cad.onshape.com/documents/2a6d830c153f862229ff478f/w/82c50406ffe66995476ba0a1/e/6ac57dbaf03b523effa40409
Everything else: https://github.com/AlessioPagliai/primo
Whole folder: https://storage.googleapis.com/riverfamily/primo/primo.zip
Print: PA-CF or PPA-CF, 0.4 nozzle. Ankle gimbal 3MF: PPA-CF, 0.2 mm, 1 wall, 90 % grid infill. Leg test plate 3MF: PLA, fit test only.
Licence: CC0, public domain.